Xiaofeng GENG, Shican LIU, Kexiang WEI, Hu DING, Xingjian JING
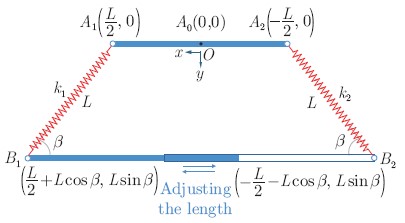
This study introduces a versatile trapezoidal X-mechanism with three degrees-of-freedom (DOFs) to enable practical nonlinear manipulation using standard mechanical components. When integrated springs and rods are arranged in a trapezoidal configuration, the mechanism exhibits rich nonlinear characteristics along multiple direct...

 Email Alert
 RSS