Applied Mathematics and Mechanics (English Edition) ›› 2026, Vol. 47 ›› Issue (9): 1943-1968.doi: https://doi.org/10.1007/s10483-026-3431-9
Previous Articles Next Articles
Zhou YANG, Xinyuan LI, Dongping JIN, Ti CHEN( )
Received:2026-02-06
Revised:2026-07-01
Online:2026-09-17
Published:2026-09-17
Contact:
Ti CHEN, E-mail: chenti@nuaa.edu.cnSupported by:2010 MSC Number:
Zhou YANG, Xinyuan LI, Dongping JIN, Ti CHEN. Dynamic modeling and control for flexible bodies with mobile control moment gyroscopes. Applied Mathematics and Mechanics (English Edition), 2026, 47(9): 1943-1968.
"
| d, | input dimensions of the radial basis function (RBF); |
| Db, | damping coefficient matrix of the flexible body; |
| E, | Young’s modulus; |
| Ea, | modal mass coefficients of the system; |
| Eb, | modal mass coefficients of the flexible body; |
| fd, | unknown external bounded disturbances; |
| FC, | Coriolis force vector; |
| Fin, | internal force vector of the structural vibration; |
| FAi, | generalized active force; |
| FIi, | generalized inertia force; |
| FEi, | generalized elastic force; |
| Gi,j, | transformation matrix from |
| | moment of inertia of the ith control moment gyroscope (CMG); |
| Jgi, | moment of inertia of the ith CMG’s gimbal; |
| Jri, | moment of inertia of the ith CMG’s rotor; |
| k, | mode order; |
| l, | output dimensions of the RBF; |
| mgi, | mass of the gimbal; |
| mri, | mass of the rotor; |
| | modal momentum coefficients of the CMGs; |
| Qgi, | mass center of the ith CMG; |
| s, | number of RBF basis functions; |
| vgi, | translational velocity of the ith CMG; |
| αi, | angular velocity of the gimbal; |
| βi, | angular velocity of the rotor; |
| λb, | stiffness coefficient matrix of the flexible body; |
| υ, | Poisson’s ratio; |
| ρm,gi, | position of the mass microelement of gimbal in |
| ρgi, | position of |
| ρm,ri, | position of the rotor’s mass microelement in |
| ηb, | modal coordinate of |
| | flexible body; |
| Γb, | body reference frame of |
| ΓI, | inertial reference frame; |
| Γgi, | gimbal-fixed frame of the ith CMG; |
| Γri, | rotor-fixed frame of the ith CMG; |
| θm,b, | rotational modal matrices; |
| | translational modal matrices; |
| Cgi,1, | coupling coefficients corresponding to |
| Cgi,2, | coupling coefficients corresponding to |
| Cgi,3, | coupling coefficients corresponding to |
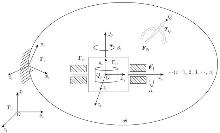
Fig. 1
Flexible cantilever body with n mobile CMGs"
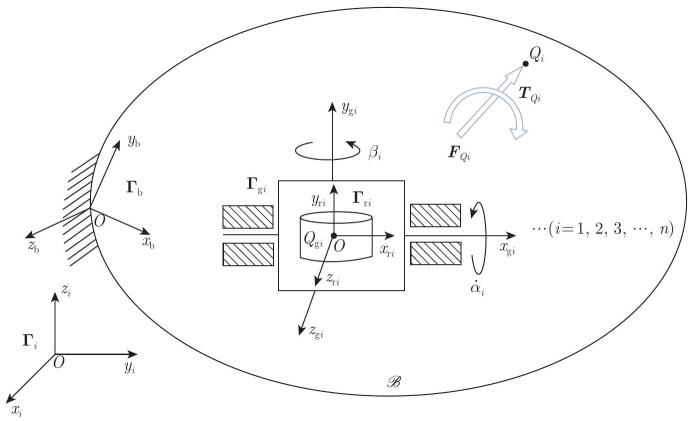
Fig. 2
Cantilever beam with mobile CMGs"
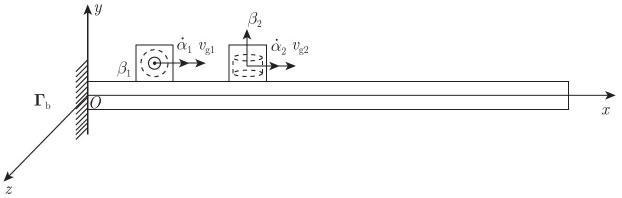
Table 1
Parameter values for the beam with mobile CMGs"
| Parameter | Value | Unit |
|---|---|---|
| Density of the flexible body | 2 700 | kg/m3 |
| Length of the flexible body | 10 | m |
| External diameter of the flexible body | 0.04 | m |
| Inside diameter of the flexible body | 0.038 | m |
| Young’s modulus, E | 70 | GPa |
| Poisson’s ratio, ν | 0.3 | – |
| Mass of the gimbal, | 0.5 | kg |
| Gimbal’s moment of inertia, | | |
| Mass of the rotor, | 0.5 | kg |
| Rotor’s moment of inertia, | | |
| Structural damping ratio | 0.001 | – |
| Rotor’s angular velocity, | 100 | rad/s |
| Rotor’s angular momentum, | 1.3 | |
| Rated gimbal-torque capacity | 4 | |
| Rated translational-force capacity | 3 | N |
Table 2
Parameters for the observer and controller"
| Parameter | Value |
|---|---|
| Diagonal gain matrices for the multivariable STD, | |
| Boundary layer for the element-wise operation in the STD, δ | 0.001 |
| Observer feedback gain matrix, | |
| Learning-rate matrix for the NN-based observer, | |
| Diagonal parameter matrix for the sliding surface, | |
| Sliding mode gain matrix, | |
| Robust switching gain, η | 2 |
| Boundary layer for the robust switching term, | 0.001 |
| Input dimensions of RBF, d | 12 |
| Number of RBF basis functions, s | 20 |
| Output dimensions of RBF, l | 6 |
| Widths of the ith receptive field, | 0.5 |
| Center vectors of RBF receptive fields, | |
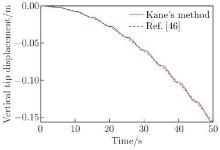
Fig. 3
Vertical tip displacement of the cantilever beam with mobile masses (color online)"
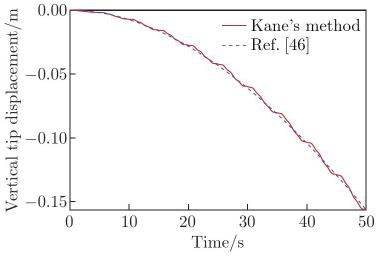
Fig. 4
Simulation results of the cantilever beam under observer: (a) estimation and error for the vibration velocity at Q1 in the y-direction; (b) estimation and error for the vibration velocity at Q2 in the y-direction; (c) estimation and error for the translation velocity of CMG 1; (d) estimation and error for the translation velocity of CMG 2 (color online)"
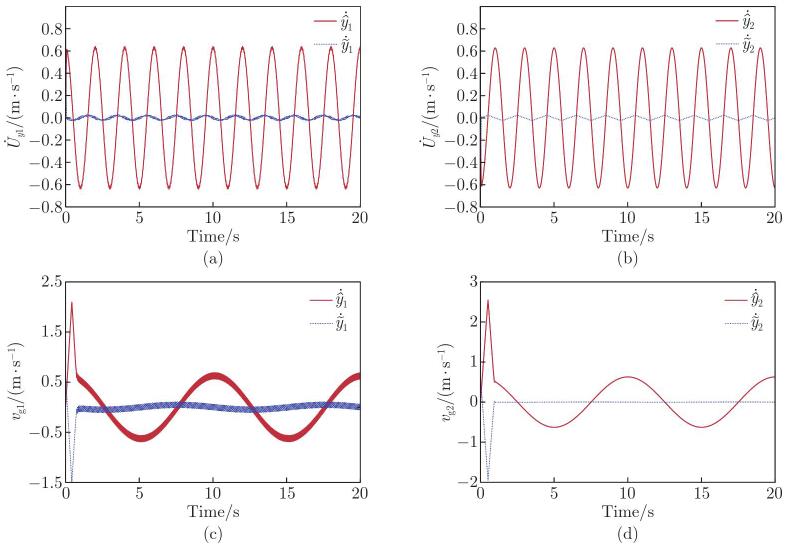
Fig. 5
System responses under external disturbances: (a) comparison of the tip displacement trajectories in the yz-plane between the COB-SMC and PD control; (b) modal coordinates under COB-SMC; (c) estimations and errors of the CMG positions; (d) estimations and errors of the CMG translational velocities; (e) estimations of the elastic displacements at Q1 defined as y^disp1; (f) estimations of the elastic displacements at Q2, defined as y^disp2; (g) gimbal angular velocities of the CMGs; (h) estimation errors of the unmeasurable modal velocities (color online)"
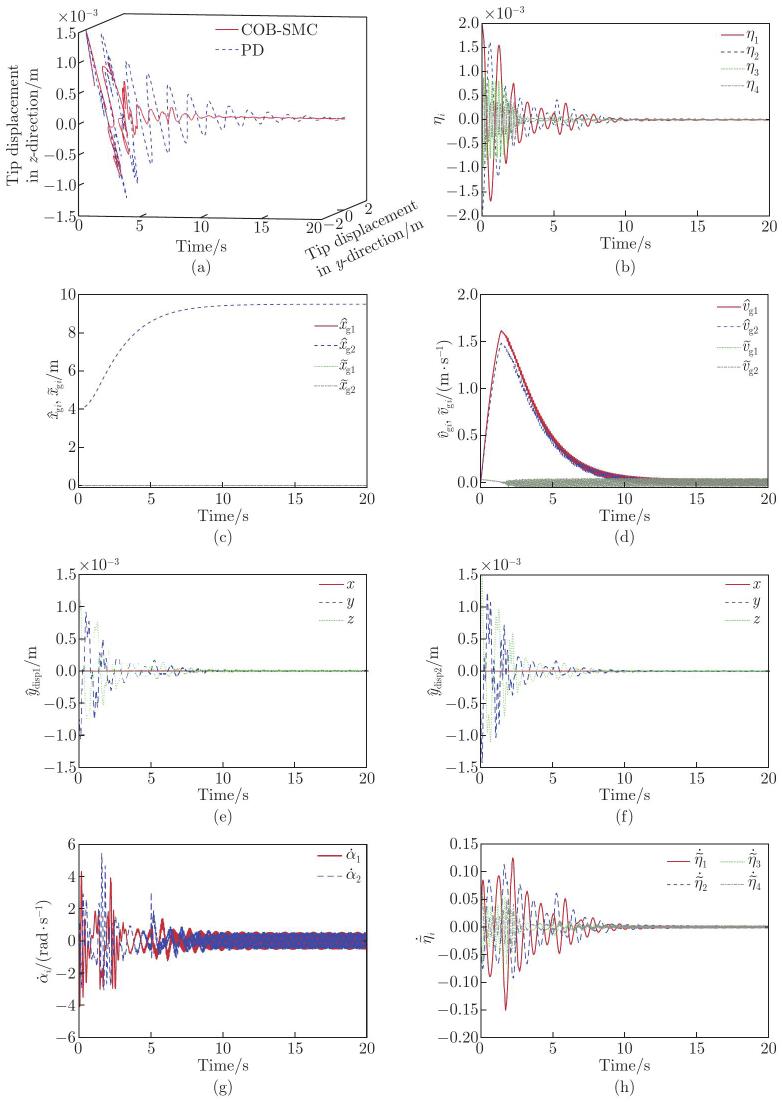
Fig. 6
System responses with fixed CMGs: (a) tip displacement; (b) modal coordinates; (c) estimations of the elastic displacements at Q1, defined as y^disp1; (d) estimations of the elastic displacements at Q2, defined as y^disp2; (e) gimbal angular velocities of the CMGs; (f) estimation errors of the unmeasurable modal velocities (color online)"
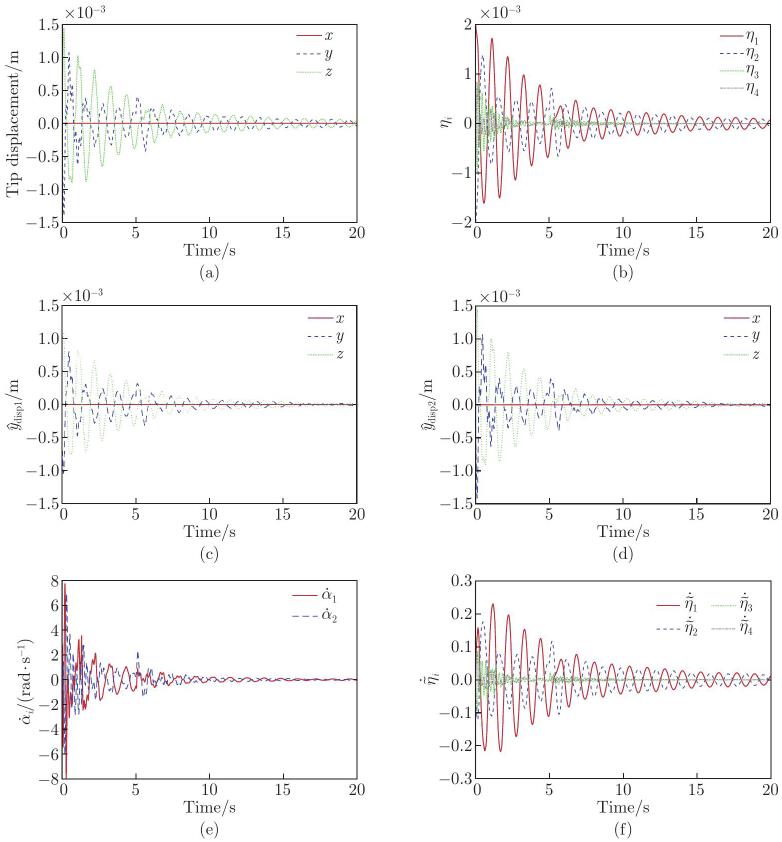
Table 3
Commanded CMG input extrema"
| Configuration | | | | |
|---|---|---|---|---|
| Mobile CMGs | 3.728 7 | 3.752 6 | 2.509 1 | 2.462 3 |
| Fixed CMGs | 3.730 4 | 3.752 6 | – | – |
Table 4
RMS tip displacement and component-wise absolute-power metric over the full simulation"
| Configuration | RMS tip displacement/m | | | |
|---|---|---|---|---|
| Fixed CMGs | | 6.06 | 0 | 6.06 |
| Mobile CMGs | | 4.34 | 11.95 | 16.29 |
| [1] | CHEN, L. F., LETU, H. S., FAN, M., SHANG, H. Z., TAO, J. H., WU, L. X., ZHANG, Y., YU, C., GU, J. B., ZHANG, N., HONG, J., WANG, Z. T., and ZHANG, T. Y. An introduction to the Chinese high-resolution earth observation system: Gaofen-1∼7 civilian satellites. Journal of Remote Sensing, 2022, 9769536 (2022) |
| [2] | TORRINI, T., GENOVA, A., ANDOLFO, S., GARGIULO, A. M., FEDERICI, P., TEODORI, R., and CIAMBELLINI, M. Real-time onboard orbit propagator for planetary missions. Astrodynamics, 10(1), 25–51 (2026) |
| [3] | CHEN, T., HE, S. Y., WANG, Y. K., WEI, Z. T., CHEN, Y. J., and TAYEBI, J. Dynamics and control for capture mode of drag-free satellite considering nonlinear electrostatic effect. Applied Mathematics and Mechanics (English Edition), 46(9), 1631–1648 (2025) https://doi.org/10.1007/s10483-025-3297-8 |
| [4] | LI, X. Y., WEI, Z. T., CHEN, T., ZHANG, A. Q., and KONG, L. B. Path planning and control of attitude maneuver of flexible spacecraft on SO(3). Aerospace Science and Technology, 178, 113057 (2026) |
| [5] | WEI, Y. Q., CHEN, Z. S., WEN, H., CHEN, T., JIN, D. P., and BAI, X. L. Ground experiment system for on-orbit operation based on hardware-in-the-loop and improved time-delay estimation. Aerospace Science and Technology, 177, 112200 (2026) |
| [6] | YANG, H. Y., HU, Q. L., DONG, H. Y., and ZHAO, X. W. ADP-based spacecraft attitude control under actuator misalignment and pointing constraints. IEEE Transactions on Industrial Electronics, 69(9), 9342–9352 (2022) |
| [7] | FALLAHIAREZOODAR, N. and ZHU, Z. H. Review of autonomous space robotic manipulators for on-orbit servicing and active debris removal. Space: Science & Technology, 5, 291 (2025) |
| [8] | ZHANG, Y. C., WU, G. Q., YANG, X. Y., and SONG, S. M. Appointed-time prescribed performance control for 6-DOF spacecraft rendezvous and docking operations under input saturation. Aerospace Science and Technology, 128, 107744 (2022) |
| [9] | ZHENG, C. D., LI, Q., YANG, H. J., and LIU, L. An integrated payload-centric control approach for multi-payload satellites. Space: Science & Technology, 5, 217 (2025) |
| [10] | WEI, Z., TAO, B., and CHEN, T. Double-loop control for handling flexible payloads by space manipulator based on differential algebraic equations. Chinese Journal of Theoretical and Applied Mechanics, 58(8), 2115–2127 (2026) |
| [11] | YUAN, J. M. Recent advance of vibration control techniques in structures. Advances in Frontier Research on Engineering Structures II, Springer Nature, Singapore (2024) |
| [12] | GUO, J. Y., YUE, C. F., JIA, S. Y., and CAO, X. B. Plate-like flexible spacecraft modeling and distribution of control moment gyroscopes. Space: Science & Technology, 3, 68 (2023) |
| [13] | SUN, J. L., CAI, Z. Z., SUN, J. H., and JIN, D. P. Dynamic analysis of a rigid-flexible inflatable space structure coupled with control moment gyroscopes. Nonlinear Dynamics, 111(9), 8061–8081 (2023) |
| [14] | LEI, Y. J., YUAN, L., ZHU, Q., WANG, Z. G., and LIU, J. A steering method with multiobjective optimizing for nonredundant single-gimbal control moment gyro systems. IEEE Transactions on Industrial Electronics, 69(4), 4177–4184 (2022) |
| [15] | ZHANG, J. R. Steering laws analysis of SGCMGs based on singular value decomposition theory. Applied Mathematics and Mechanics (English Edition), 29(8), 1013–1021 (2008) https://doi.org/10.1007/s10483-008-0805-2 |
| [16] | CREASER, C. and BAUER, R. Logic-based gimbal compensator for the double-gimbal scissored-pair control moment gyroscope using magnetic torquers. Advances in Space Research, 73(1), 254–270 (2024) |
| [17] | JIA, S. Y. and SHAN, J. J. Flexible structure vibration control using double-gimbal variable-speed control moment gyros. Journal of Guidance, Control, and Dynamics, 44(5), 954–966 (2021) |
| [18] | DAS, G. and SINHA, M. Satellite attitude control using faulty double gimbal variable speed control moment gyroscope. Journal of Guidance, Control, and Dynamics, 47(6), 1196–1212 (2024) |
| [19] | LIU, F., GAO, Y., and ZHANG, W. W. Large angle maneuver and high accuracy attitude pointing steering law for variable speed control momentum gyroscopes. Journal of the Franklin Institute, 358(7), 3441–3469 (2021) |
| [20] | WIE, B. Singularity analysis and visualization for single-gimbal control moment gyro systems. Journal of Guidance, Control, and Dynamics, 27(2), 271–282 (2004) |
| [21] | LEEGHIM, H., LEE, I. H., LEE, D. H., BANG, H., and PARK, J. O. Singularity avoidance of control moment gyros by predicted singularity robustness: ground experiment. IEEE Transactions on Control Systems Technology, 17(4), 884–891 (2009) |
| [22] | HU, Q., JIA, Y. H., and XU, S. J. Recursive dynamics algorithm for multibody systems with variable-speed control moment gyroscopes. Journal of Guidance, Control, and Dynamics, 36(5), 1388–1398 (2013) |
| [23] | HU, Q., JIA, Y. H., and XU, S. J. Dynamics and vibration suppression of space structures with control moment gyroscopes. Acta Astronautica, 96, 232–245 (2014) |
| [24] | WANG, X. M., WANG, E. M., XING, J., and ZHOU, W. Y. A novel vibration-reduction motion planning method for fast moving mass traveling along flexible structures. Nonlinear Dynamics, 111(20), 19151–19170 (2023) |
| [25] | PILIPCHUK, V., SHAW, S. W., and CHALHOUB, N. Control of dumbbell satellite orbits using moving mass actuators. Nonlinear Dynamics, 110(2), 1373–1391 (2022) |
| [26] | DADOULIS, G., MANOLIS, G. D., KATAKALOS, K., DRAGOS, K., and SMARSLY, K. Damage detection in lightweight bridges with traveling masses using machine learning. Engineering Structures, 322, 119216 (2025) |
| [27] | ZHANG, J. Q., KONG, X. L., LIU, C., DENG, Q., and SHI, K. K. Agile attitude maneuver with active vibration-suppression for flexible spacecraft. Journal of the Franklin Institute, 359(3), 1172–1195 (2022) |
| [28] | TAYEBI, J., CHEN, Y. J., CHEN, T., and JIA, S. Y. Attitude control of flexible satellite via three-dimensional magnetically suspended wheel. Applied Mathematics and Mechanics (English Edition), 46(3), 555–572 (2025) https://doi.org/10.1007/s10483-025-3232-7 |
| [29] | CHEN, P. C., SUGIARTO, B. J., and CHIEN, K. Y. Performance-based optimization of LQR for active mass damper using symbiotic organisms search. Smart Structures and Systems, 27, 705–717 (2021) |
| [30] | WANG, J., ZHANG, X. N., LIU, Y. F., QIN, Z. Y., MA, L., and CHU, F. L. Rotor vibration control via integral magnetorheological damper. International Journal of Mechanical Sciences, 252, 108362 (2023) |
| [31] | MA, X. F., LIU, Y. X., DENG, J., GAO, X., and CHENG, J. F. A compact inchworm piezoelectric actuator with high speed: design, modeling, and experimental evaluation. Mechanical Systems and Signal Processing, 184, 109704 (2023) |
| [32] | LI, P., JIN, F., and MA, J. X. One-dimensional dynamic equations of a piezoelectric semiconductor beam with a rectangular cross section and their application in static and dynamic characteristic analysis. Applied Mathematics and Mechanics (English Edition), 39(5), 685–702 (2018) https://doi.org/10.1007/s10483-018-2325-6 |
| [33] | PENG, H., YANG, Y. L., YIN, P., and SUN, R. Y. Theoretical and experimental study on self-synchronization of anti-resonance system with three co-rotating rotors driven by exciters. Nonlinear Dynamics, 113(16), 21095–21117 (2025) |
| [34] | SACHSE, R., GEIGER, F., VON SCHEVEN, M., and BISCHOFF, M. Motion design with efficient actuator placement for adaptive structures that perform large deformations. Frontiers in Built Environment, 7, 545962 (2021) |
| [35] | ALBAHAR, A., KIM, I., WANG, X., and YUE, X. W. Physics-constrained Bayesian optimization for optimal actuators placement in composite structures assembly. IEEE Transactions on Automation Science and Engineering, 20(4), 2772–2783 (2023) |
| [36] | MEHRABIAN, A. R. and YOUSEFI-KOMA, A. A novel technique for optimal placement of piezoelectric actuators on smart structures. Journal of the Franklin Institute, 348(1), 12–23 (2011) |
| [37] | LI, Y. M., MA, S., LI, K. W., and TONG, S. C. Adaptive fuzzy output feedback fault-tolerant control for active suspension systems. IEEE Transactions on Intelligent Vehicles, 9(1), 2469–2478 (2024) |
| [38] | LIU, Y. Q., WANG, J. W., WU, Z. Z., REN, Z. G., and XIE, S. L. Robust H∞ control for semilinear parabolic distributed parameter systems with external disturbances via mobile actuators and sensors. IEEE Transactions on Cybernetics, 53(8), 4880–4893 (2023) |
| [39] | WEI, Y., LIU, X., ZHAN, B., WEN, H., and CHEN, T. Review of space robotics technology for on-orbit construction of ultra-large optical systems. Acta Astronautica, 242, 141–157 (2026) |
| [40] | CHEN, T., KONG, D. K., DING, F. Y., YANG, Z., and LI, D. D. Attitude regulation and vibration suppression of a rotating flexible beam with a moving actuator. Journal of the Franklin Institute, 362(12), 107873 (2025) |
| [41] | QI, R., ZHANG, Y., JIANG, H., and ZHONG, R. Dynamic analysis of tethered defunct satellites with solar panels. Astrodynamics, 8(2), 297–309 (2024) |
| [42] | SARKAR, S. and FITZGERALD, B. Use of Kane’s method for multi-body dynamic modelling and control of spar-type floating offshore wind turbines. Energies, 14(20), 6635 (2021) |
| [43] | RONG, B., RUI, X. T., TAO, L., and WANG, G. P. Theoretical modeling and numerical solution methods for flexible multibody system dynamics. Nonlinear Dynamics, 98(2), 1519–1553 (2019) |
| [44] | TANNER, H. G. and KYRIAKOPOULOS, K. J. Mobile manipulator modeling with Kane’s approach. Robotica, 19(6), 675–690 (2001) |
| [45] | CHEN, B., ZHANG, H. G., and LIN, C. Observer-based adaptive neural network control for nonlinear systems in nonstrict-feedback form. IEEE Transactions on Neural Networks and Learning Systems, 27(1), 89–98 (2016) |
| [46] | CHAWDA, D. and MURUGAN, S. Dynamic response of a cantilevered beam under combined moving moment, torque and force. International Journal of Structural Stability and Dynamics, 20(5), 2050065 (2020) |
| [1] | Hefan DONG, Linjuan WANG. Locally resonant plate model considering the rotation coupling effect [J]. Applied Mathematics and Mechanics (English Edition), 2026, 47(2): 369-388. |
| [2] | Yongzhe LI, Yongqiang LI, Gaoge LIANG, Quanxing LIU, Yong XIAO. Single-phase multi-resonant metabeam for broadband reduction of multi-polarization low-frequency vibration [J]. Applied Mathematics and Mechanics (English Edition), 2025, 46(12): 2265-2280. |
| [3] | Yunting HAN, Hui HU, Haoran SUN, Xi SHI. A new rope-sheave traction contact force model incorporating complex geometric features developed through parameter identification methods [J]. Applied Mathematics and Mechanics (English Edition), 2025, 46(10): 1983-2006. |
| [4] | Shuo WANG, Anshuai WANG, Yansen WU, Xiaofeng LI, Yongtao SUN, Zhaozhan ZHANG, Qian DING, G. D. AYALEW, Yunxiang MA, Qingyu LIN. Ultra-wide band gap and wave attenuation mechanism of a novel star-shaped chiral metamaterial [J]. Applied Mathematics and Mechanics (English Edition), 2024, 45(7): 1261-1278. |
| [5] | Xingjian DONG, Shuo WANG, Anshuai WANG, Liang WANG, Zhaozhan ZHANG, Yuanhao TIE, Qingyu LIN, Yongtao SUN. Low-frequency bandgap and vibration suppression mechanism of a novel square hierarchical honeycomb metamaterial [J]. Applied Mathematics and Mechanics (English Edition), 2024, 45(10): 1841-1856. |
| [6] | Yang JIN, Tianzhi YANG. Enhanced vibration suppression and energy harvesting in fluid-conveying pipes [J]. Applied Mathematics and Mechanics (English Edition), 2023, 44(9): 1487-1496. |
| [7] | Xiuting SUN, Yipeng QU, Feng WANG, Jian XU. Effects of time-delayed vibration absorber on bandwidth of beam for low broadband vibration suppression [J]. Applied Mathematics and Mechanics (English Edition), 2023, 44(10): 1629-1650. |
| [8] | Kai WANG, Jiaxi ZHOU, Dongguo TAN, Zeyi LI, Qida LIN, Daolin XU. A brief review of metamaterials for opening low-frequency band gaps [J]. Applied Mathematics and Mechanics (English Edition), 2022, 43(7): 1125-1144. |
| [9] | Ling TAO, Zhongpan LI, Yan LI, Huijian CHEN, Zhiqiang FENG. Nonsmooth dynamic analysis of rigid-flexible interaction collision [J]. Applied Mathematics and Mechanics (English Edition), 2022, 43(11): 1731-1746. |
| [10] | Pengcheng ZHAO, Kai ZHANG, Cheng ZHAO, Zichen DENG. Multi-resonator coupled metamaterials for broadband vibration suppression [J]. Applied Mathematics and Mechanics (English Edition), 2021, 42(1): 53-64. |
| [11] | A. M. ZENKOUR, H. D. EL-SHAHRANY. Vibration suppression of magnetostrictive laminated beams resting on viscoelastic foundation [J]. Applied Mathematics and Mechanics (English Edition), 2020, 41(8): 1269-1286. |
| [12] | Xiaodong YANG, Shaowen WANG, Wei ZHANG, Zhaohong QIN, Tianzhi YANG. Dynamic analysis of a rotating tapered cantilever Timoshenko beam based on the power series method [J]. Applied Mathematics and Mechanics (English Edition), 2017, 38(10): 1425-1438. |
| [13] | ZHANG Ding-Guo;XIAO Jian-Jiang. A DYNAMIC MODEL FOR ROCKET LAUNCHER WITH COUPLED RIGID AND FLEXIBLE MOTION [J]. Applied Mathematics and Mechanics (English Edition), 2005, 26(5): 609-. |
| [14] | Xiao Shifu;Chen Bin. MODELING AND BIFURCATION ANALYSIS OF THE CENTRE RIGID-BODY MOUNTED ON AN EXTERNAL TIMOSHENKO BEAM [J]. Applied Mathematics and Mechanics (English Edition), 1999, 20(12): 1389-1393. |
| [15] | Hu Zhendong;Hong Jiazhen. MODELING AND ANALYSIS OF A COUPLED RIGID-FLEXIBLE SYSTEM [J]. Applied Mathematics and Mechanics (English Edition), 1999, 20(10): 1167-1174. |
| Viewed | ||||||
|
Full text |
|
|||||
|
Abstract |
|
|||||
 Email Alert
 RSS
